Identity_Matrix (About Me)
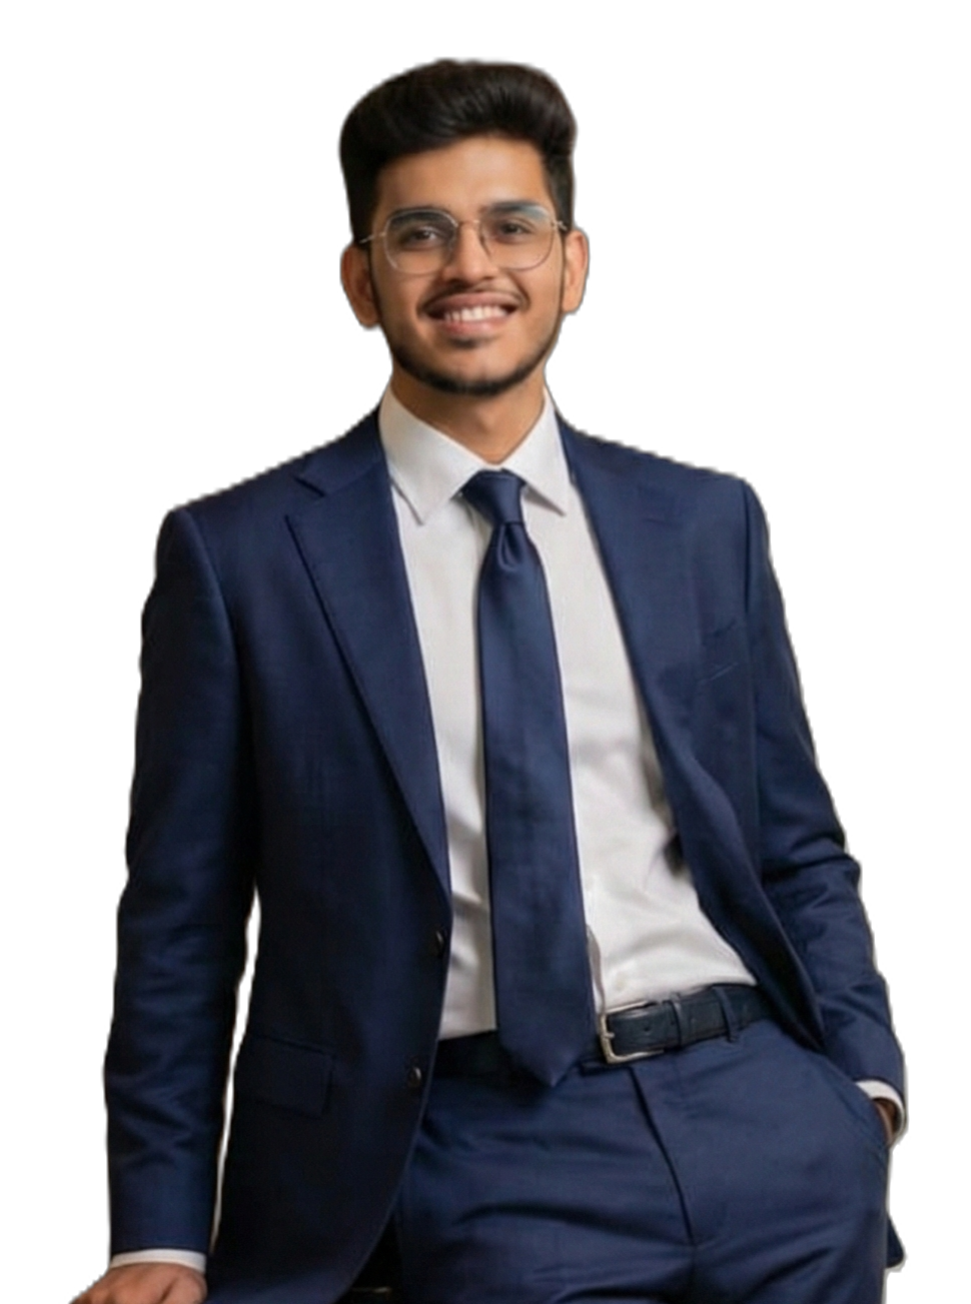
AI Engineer & Robotics Specialist
I build production-grade AI systems, including multi-agent pipelines, RAG architectures, and LLM applications, currently deployed in industrial automation at ALMAWATECH GmbH. I design multi-agent orchestration layers, hybrid RAG pipelines combining vector search with semantic retrieval (Qdrant, ChromaDB, FAISS), and ship LLM-powered features via FastAPI, React, and Docker on cloud infrastructure.
I recently completed my M.Sc. in Automation & Robotics at TU Dortmund. My thesis developed a 6G-enabled collaborative perception framework for multi-robot warehouse systems using Graph Neural Networks and mmWave radar for real-time occupancy prediction, validated with OptiTrack motion capture. I build systems that don't just compute; they operate in the real world.
Neural_Capacity (Technical Expertise)
Programming Languages
 Python
 C++
 MATLAB
 Bash
 JS
 SQL
AI & Machine Learning
 PyTorch
 TensorFlow
 OpenCV
 Scikit-learn
 Pandas
Generative AI & LLMs
 LangChain
 HuggingFace
 CrewAI
 AutoGen
 n8n
 RAG
Robotics & Automation
 ROS/ROS2
 Isaac Sim
 Gazebo
Cloud & DevOps
 AWS
 Docker
 Kubernetes
 GitHub
Actions
 Grafana
 Git
 Linux
Execution_Logs (Professional Experience)
AI Engineer – Werkstudent
- Designing and deploying production multi-agent AI systems with LLM orchestration, hybrid RAG, and vector databases for industrial knowledge retrieval.
- Building automated pipelines for lead discovery, content generation, and customer support deployed via CI/CD on cloud infrastructure.
- Implementing hybrid retrieval combining BM25, dense embeddings, and cross-encoder reranking with multilingual support and safety validation.
- Developing full-stack applications (React + FastAPI) with voice input, document generation, and real-time streaming in production.
Research Assistant – Information Processing Laboratory
- Designed deep learning models for intelligent signal interpretation in complex electromagnetic systems.
- Applied reinforcement learning for adaptive optimization and real-time parameter tuning in dynamic environments.
- Improved signal processing precision in high-frequency industrial applications via supervised ML techniques.
Master's Thesis – Collaborative Robotic Perception
- Developed 6G-enabled collaborative perception for multi-robot systems using mmWave radar technology.
- Implemented Graph Neural Network architectures for real-time occupancy prediction in warehouse environments.
- Conducted comprehensive validation using dual robotic platforms with motion capture ground truth systems.
Robotics Engineering Intern – Autonomous Systems
- Designed and deployed Autonomous Mobile Robot for industrial logistics and inspection automation applications.
- Integrated LiDAR, IMU, and camera systems for robust SLAM-based navigation in dynamic industrial environments.
- Developed real-time path planning and obstacle avoidance algorithms using ROS framework.
Academic_Core (Education)
Master of Science in Automation and Robotics
TU Dortmund (Technical University Dortmund)Specialization Modules:
Bachelor of Engineering in Robotics and Automation
PSG College of TechnologyCore Focus:
Recommendations: Dr. B. Vinod, Dr. Suresh M
Deployed_Modules (Featured Projects)
AutoGen Content Creation Pipeline
An enterprise-grade multi-agent AI system designed to automate end-to-end content creation workflows.
GitHub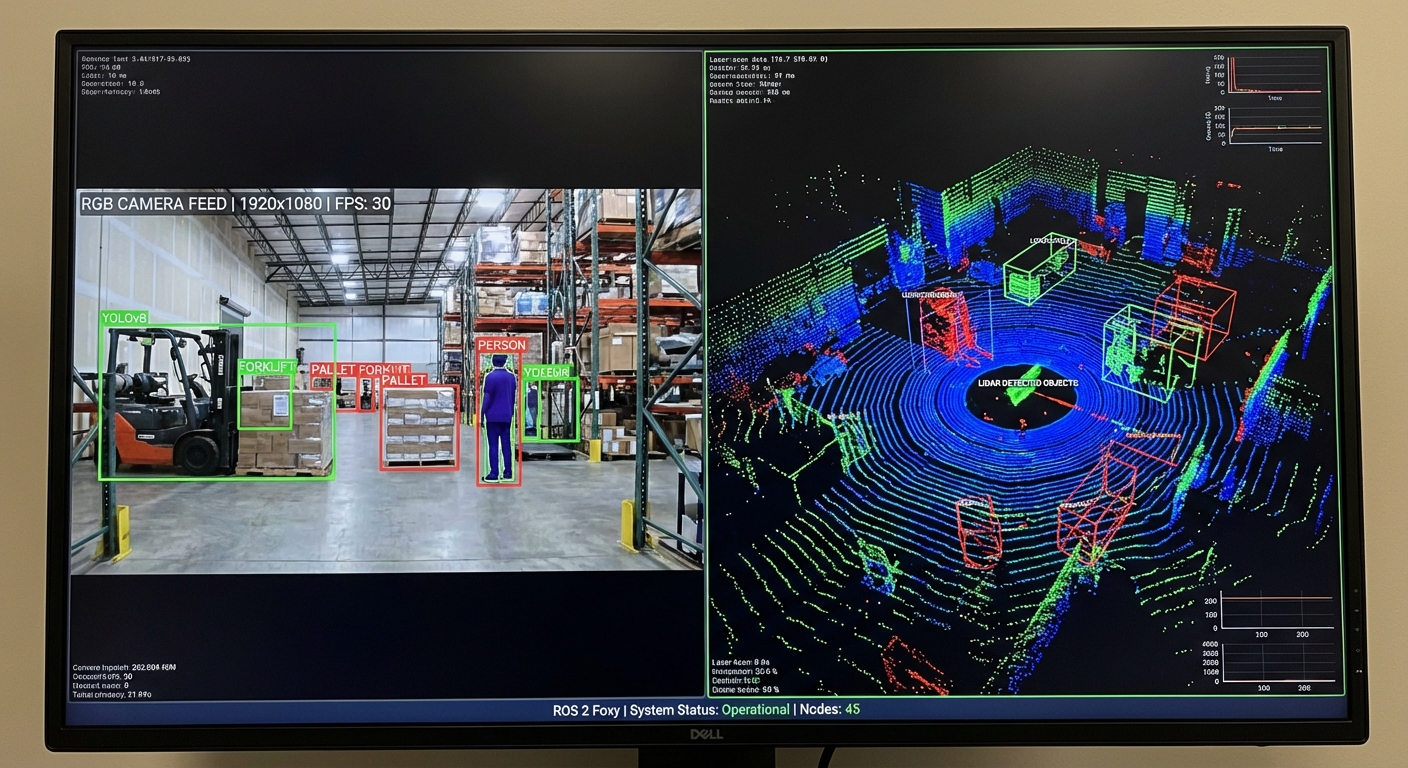
RoboVision-3D
Computer Vision system for Indoor Robotics with Multi-Sensor Fusion integrating RGB-D cameras and LiDAR.
GitHub
Context-Window-Aware Chatbot
Production-style LLM chatbot with intelligent context window management, long-term memory, and safety guardrails.
GitHub
Autonomous Market Intelligence System
CrewAI-powered multi-agent system with four specialized agents for autonomous market intelligence.
GitHub
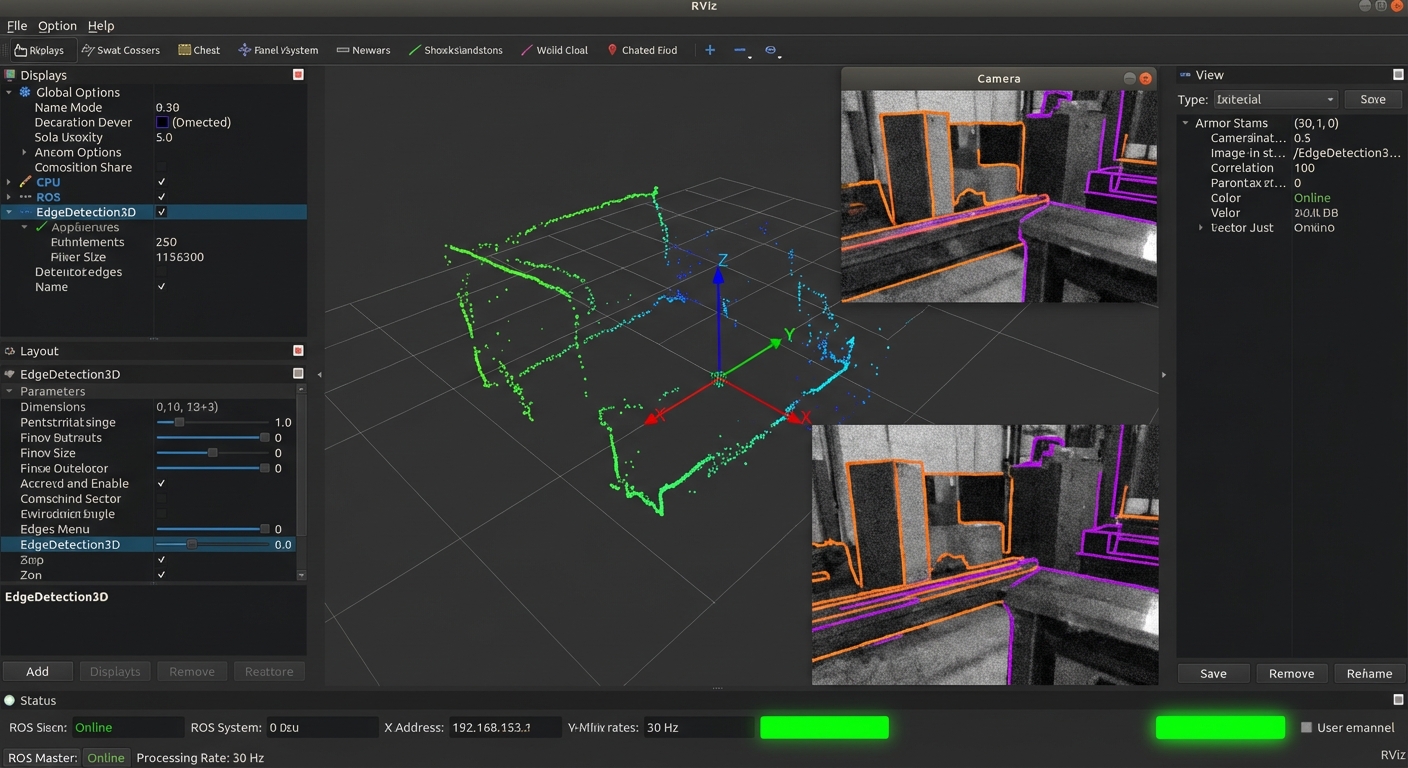
Edge Detection 3D Vision
3D Vision System with Real-Time Image Processing and modular edge detection with ROS.
GitHub
GraphRAG: Knowledge Graph-Enhanced RAG
Production-ready RAG system combining knowledge graphs with vector search for multi-hop reasoning.
GitHub
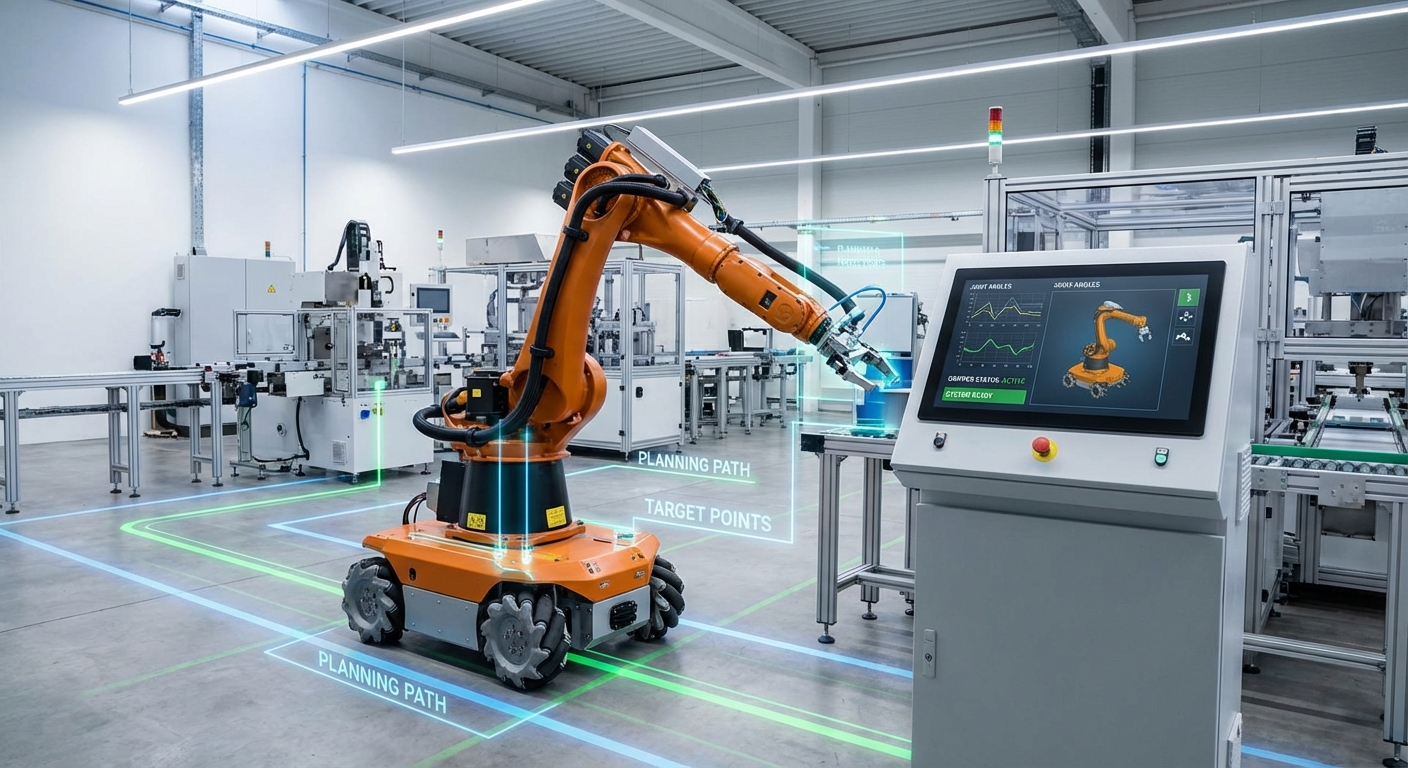
Robotic Automation Platform
Multi-DOF Robotic Arm with Omnidirectional Base for factory automation with adaptive motion.
Repository Coming Soon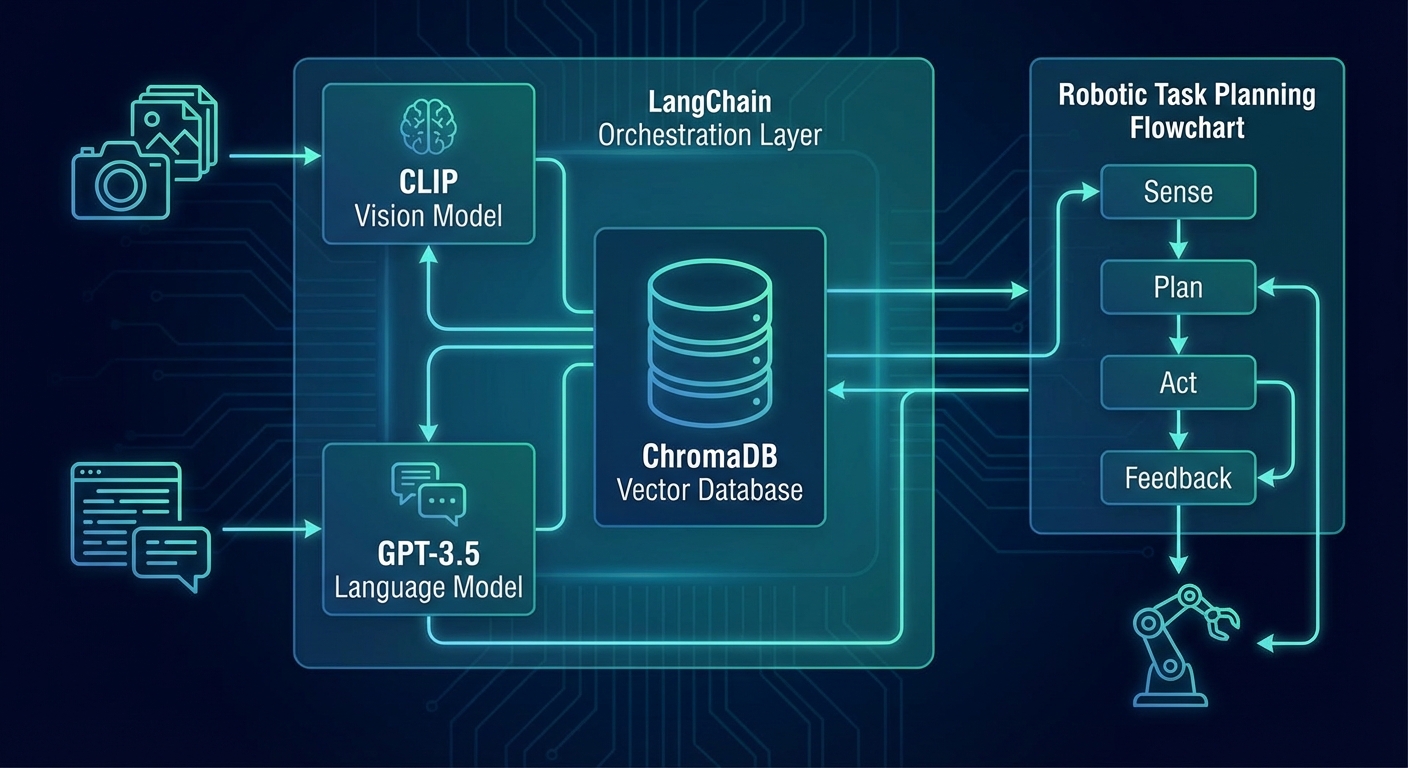
Multi-modal AI Framework
Multi-Agent System integrating CLIP vision, GPT-3.5 NLP, and RAG for robotic task planning.
GitHub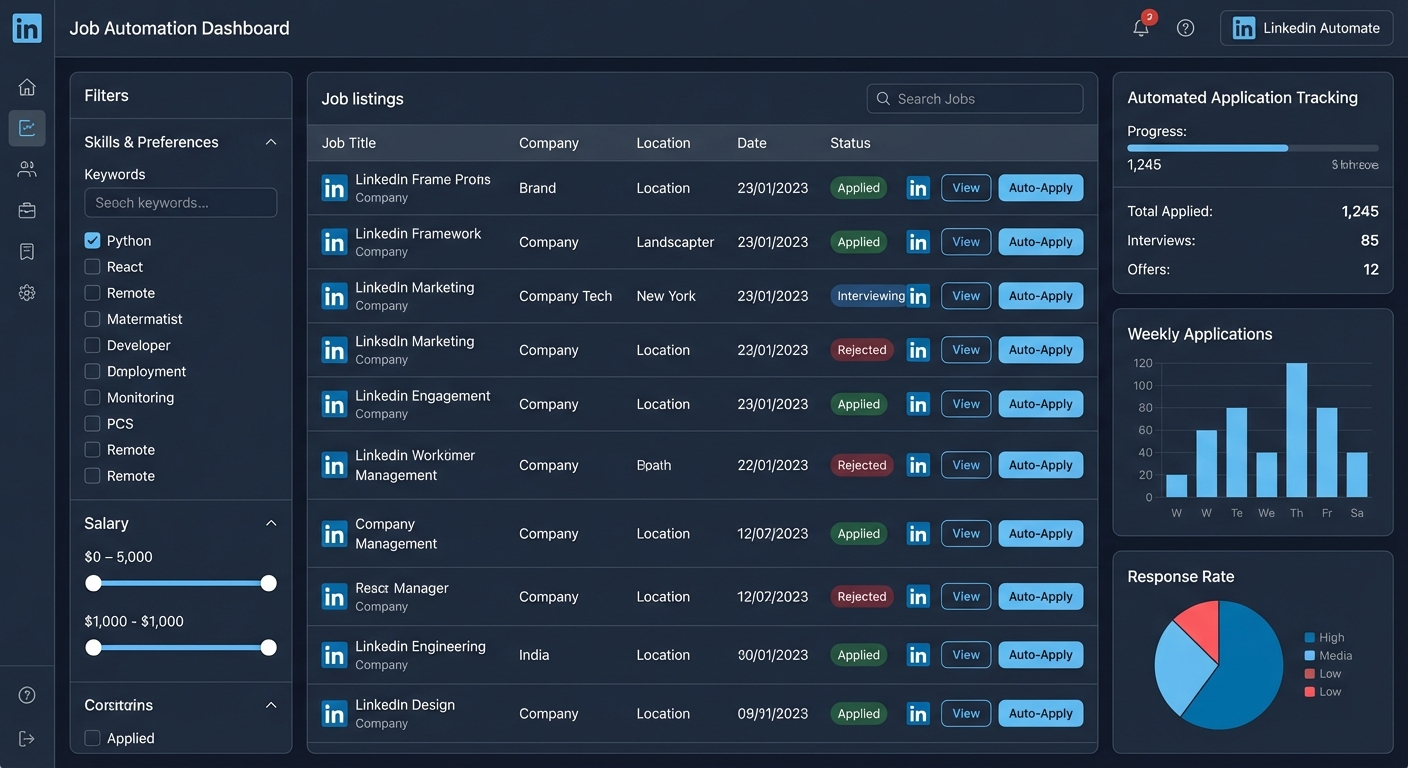
LinkedIn Job Automation
Automated LinkedIn job search and application tracking system with intelligent filtering.
GitHub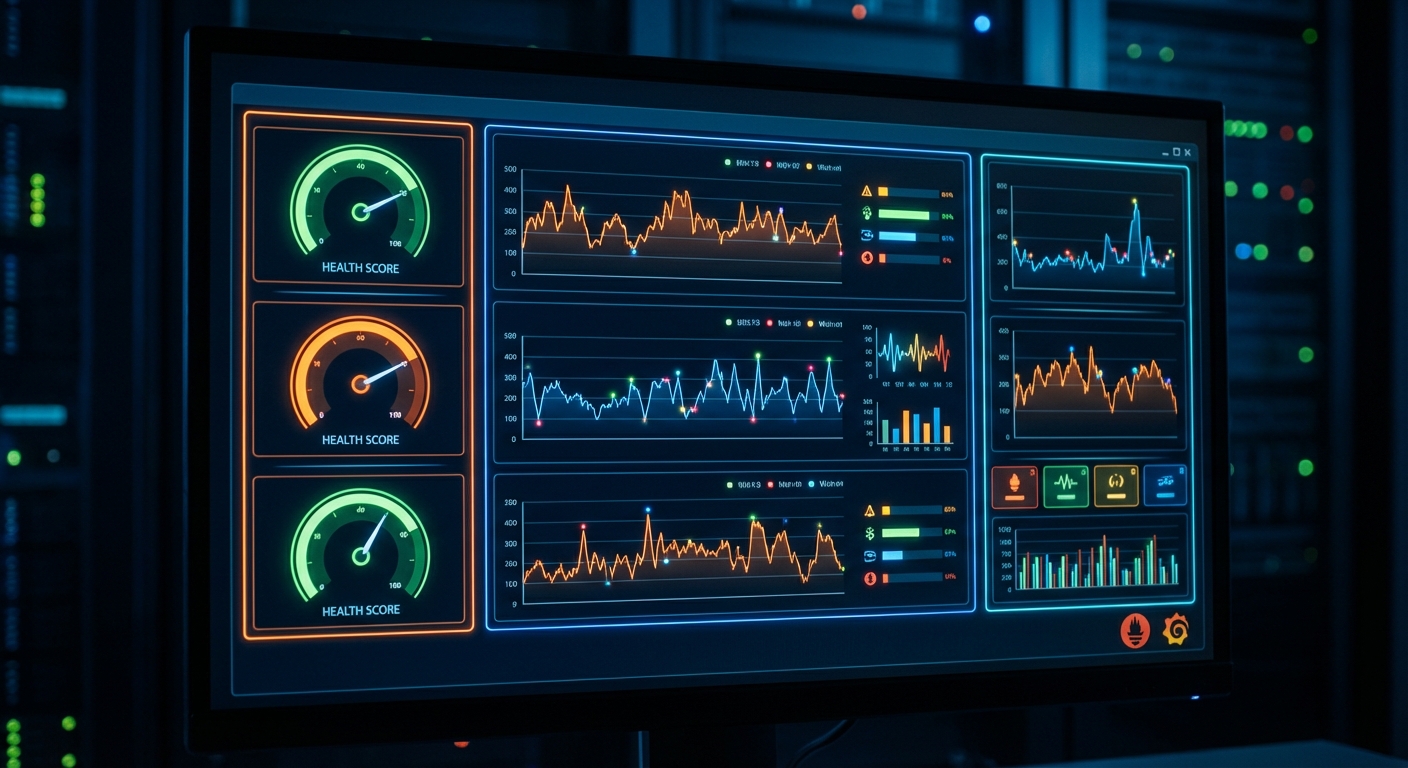
Smart System Health Monitor
Production-ready observability platform with predictive analytics using Prometheus.
GitHubEncrypted_Credentials (Certifications)
Research_Output (Research Publications)
RFID based Human Following Load Carrier
> SYSTEM_ABSTRACT: Design and implementation of an autonomous robot system capable of tracking and following humans while assisting in load carrying tasks using RFID triangulation.
Development Of Robotic Arm On An Omnidirectional Base
> SYSTEM_ABSTRACT: Design and development of a multi-degree-of-freedom robotic arm integrated with an omnidirectional mobile base (Mecanum drive) for enhanced maneuverability and workspace.